Choose a photoelectric speed sensor by defining the real rotational speed and direction monitoring task before comparing product families. Record the target or measured object, operating range, motion, mounting geometry, environment, controller interface, and acceptance test. Use the worst permitted condition rather than the easiest sample, and verify every numerical limit against the current data sheet for the exact model. A category description can identify a technology direction, but it cannot prove model-level distance, response, accuracy, ingress protection, temperature limits, wiring, or certification.
Define the Selection Boundary
The primary task is photoelectric RPM sensor by mark contrast and response frequency. This article treats that phrase as one engineering decision, not as a claim that every product in a category fits the application. The boundary includes the actual target or measured object, minimum and maximum operating condition, installation geometry, control interface, environment, consequence of failure, and evidence required for approval.
A photoelectric speed sensor must produce a usable signal through startup, normal running, coast-down, reverse motion, and minimum speed where applicable. Keep technology selection separate from model approval. First choose the sensing principle and application architecture, then validate the exact device against the real target, installation, signal chain, environment, and acceptance evidence.
Define: Photoelectric Speed Sensor For Non Contact Rpm Measurement
The phrase photoelectric speed sensor for non contact RPM measurement defines the product entity by function, not by appearance. For photoelectric speed sensor, confirm the sensing principle, intended target, output expected by the controller, and the boundary between detection and measurement. A product photo or category label cannot establish those capabilities. The entity definition is complete only when an exact model and current document set support the application.
Apply: Optical Sensor For Conveyor And Shaft Speed Detection
Use optical sensor for conveyor and shaft speed detection as an application statement only after the physical task is documented. Identify the target, process sequence, normal and abnormal states, operating speed, installation geometry, contaminants, and consequence of a missed or false event. Keep technology selection separate from model approval. First choose the sensing principle and application architecture, then validate the exact device against the real target, installation, signal chain, environment, and acceptance evidence. The application fit should be demonstrated on representative hardware; an industry name by itself is not evidence of suitability.
Select: Photoelectric Rpm Sensor By Mark Contrast And Response Frequency
For photoelectric RPM sensor by mark contrast and response frequency, build a selection window with minimum, normal, and maximum conditions. Compare candidates on the same dimensions: target behavior, usable range, mechanical tolerance, response, interface, environment, and required documents. Reject any candidate whose exact-model evidence does not cover a mandatory condition. The remaining candidate still requires a sample test using written pass/fail criteria.
Compare: Photoelectric Speed Sensor Vs Hall Gear Sensor
Compare photoelectric speed sensor vs Hall gear sensor using one decision table and identical test conditions. Define the common task first, then compare target limits, measurement or switching behavior, mounting, setup effort, response, environment, diagnostics, and failure modes. Do not declare a universal winner: state which option fits each bounded condition and what evidence is still required.
Troubleshoot: Optical Speed Sensor Instability From Dust Vibration And Ambient Light
Use optical speed sensor instability from dust vibration and ambient light as a symptom-led diagnostic task. Reproduce the symptom safely, confirm the real process state, inspect the target and sensing interface, measure alignment or gap through a complete cycle, verify power and controller status, and change one factor at a time. Preserve the result before and after each correction so the root cause is not hidden by simultaneous adjustments.
When should I use a photoelectric speed sensor instead of a Hall or magnetic pickup?
Select the sensing principle that directly observes the required rotational speed and direction monitoring event, then eliminate candidates that cannot tolerate the real target variation, geometry, timing, environment, or interface. For photoelectric speed sensor, the family name alone is not a recommendation: the actual target and worst machine state must remain inside the documented operating boundary. A representative test should include the condition most likely to reduce signal margin or create a false event.
Verification sequence
- State the required detection or measurement event.
- List the worst target variants.
- Identify technologies that cannot observe the event directly.
- Test the selected principle on representative samples.
- Include tooth or marker geometry, air gap, runout, speed range, and pulse capture.
How do mark contrast, target count per revolution and response frequency affect optical RPM measurement?
Specify performance as a bounded operating window, not a single headline value. Record minimum, normal, and maximum conditions, add mechanical and process tolerances, and define the acceptance margin. For photoelectric speed sensor, distinguish nominal range from assured operation, resolution from accuracy, response time from total event-capture time, and reference-target data from the real target. Only exact-model values with stated test conditions belong in the design calculation.
Verification sequence
- Record minimum, normal, and maximum requirements.
- Separate nominal, assured, repeatability, accuracy, and response terms.
- Add mechanical and process tolerance.
- Bind every design value to an exact-model source.
- Include tooth or marker geometry, air gap, runout, speed range, and pulse capture.
Why does a photoelectric RPM sensor become unstable because of dust, vibration or ambient light?
Troubleshoot from the observable symptom and the lowest-risk checks first. Confirm the real process state, inspect the sensing face or actuator, measure gap and alignment through a complete cycle, verify supply and controller status, and compare the installed model code with its documents. Common causes for photoelectric speed sensor include contamination, target variation, bracket movement, cable damage, incorrect logic, filtering, and operation outside the verified boundary. Change one factor at a time and retain the before-and-after result.
Verification sequence
- Capture the symptom before changing settings.
- Check target, mechanics, contamination, power, and controller state.
- Change one factor at a time.
- Retest the full machine cycle and retain evidence.
- Include tooth or marker geometry, air gap, runout, speed range, and pulse capture.
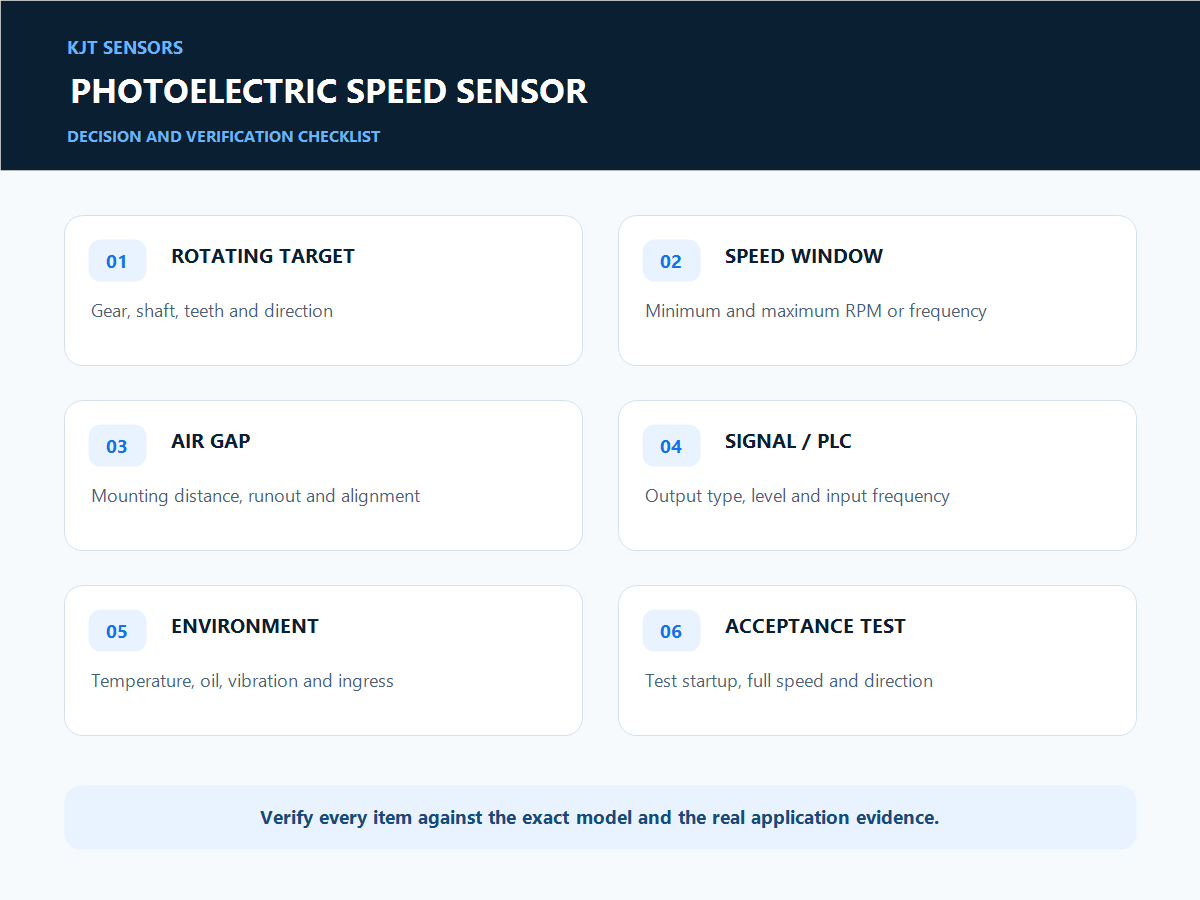
Complete the Article-Specific Decision Matrix
| Decision | Rule | Evidence before approval |
|---|---|---|
| Rotating target | Record tooth or marker geometry, speed range, direction, and air gap | Rotating-target drawing and pulse test |
| Operating window | Record minimum, normal, and maximum conditions with tolerance | Exact-model data sheet and calculation |
| Mounting | Check space, alignment, clearance, mechanical travel, and service access | Approved drawing and installation review |
| Electrical or data interface | Match supply, output, logic, timing, connector, and controller | Wiring or protocol document and I/O test |
| Environment | List temperature, ingress, chemicals, vibration, contamination, and ambient effects | Model limits and representative environmental test |
| Acceptance | Define pass/fail behavior before ordering | Commissioning record and retained evidence |
Do not populate this matrix with assumed values. Use the exact-model data sheet, drawing, wiring or protocol document, certificate where applicable, and a controlled application test.
Validate the Candidate Under Worst-Case Conditions
Run the rotating target from standstill through minimum and maximum speed, including acceleration, coast-down, runout, reverse rotation where applicable, and worst air gap. Confirm pulse amplitude or logic, phase, frequency, controller capture, and cable-noise immunity.
Use a controlled sequence:
- Record model identity and document revision.
- Photograph or measure the approved installation geometry.
- Establish a normal baseline at the controller.
- Exercise each minimum and maximum condition.
- Introduce one credible disturbance at a time.
- Record pass, fail, invalid, and recovery behavior.
- Repeat after final installation if the fixture changed.
Diagnose Failures Without Masking the Cause
| Symptom | First checks | Controlled action |
|---|---|---|
| No pulses | Air gap, target, supply, amplitude, pinout | Verify the evidence, correct one cause, and repeat the acceptance test |
| Wrong speed | Teeth-per-revolution, filtering, scaling | Verify the evidence, correct one cause, and repeat the acceptance test |
| Direction error | Channel order, phase, wiring, target geometry | Verify the evidence, correct one cause, and repeat the acceptance test |
Stop diagnosis before bypassing guards, emergency circuits, hazardous-area controls, or site isolation procedures. High-consequence behavior requires the responsible engineer.
Prepare the Technical Inquiry
Send KJT Sensors the application function, target or process description, operating window, mounting drawing, speed or timing, environment, supply and controller interface, connector or protocol, destination market, required documents, prototype quantity, and written sample-test criteria. Request the current exact-model data sheet and drawing with the response.
Related KJT Sensors Guides
- How to Choose a Speed Sensor for Shafts, Gears and Conveyors — Review the broader product-family selection framework before narrowing the model.
- Hall-Effect vs Passive Magnetic Gear Speed Sensors: Which Should You Use? — Compare this adjacent selection task to keep the application boundary and evidence requirements distinct.
- How to Choose a Gear Speed Sensor for Shaft RPM Measurement — Compare this adjacent selection task to keep the application boundary and evidence requirements distinct.
- How to Choose a Laser Photoelectric Sensor for Small-Target and Edge Detection — Compare optical event detection with rotational-speed signal generation and pulse capture.
Conclusion
Select photoelectric speed sensor by matching the technology to the real task and then proving the exact model across the full operating boundary. The decision is complete only when mechanical fit, signal behavior, environment, controller response, documentation, and worst-case sample testing agree. Category descriptions support discovery; they do not replace model-level engineering approval.
References
- KJT Sensors photoelectric speed sensor category — family-level context supplied in the approved brief; verify the live page and exact-model documents before publication.
https://www.kjt-sensors.com/
KJT Sensors
About Author
